SIMULATE
The terrain, contact, sensors and surprising details a machine will eventually have to understand-generated in the formats robotics teams already run.
The Voxity system 01-03
We build the entire learning loop so each part can make the next one more truthful.
The terrain, contact, sensors and surprising details a machine will eventually have to understand-generated in the formats robotics teams already run.
Training and evaluation built around what a machine actually achieved, not simply what it was told to do.
The distance between a demo and a machine that works unattended is the work. We close that distance deliberately.
Product field note 01
01 / SIMULATION
Where robots learn, before the real world.
Describe a world in a sentence, or start from a photo, and get one a robot simulator can open. Geometry, materials, terrain, sensors and physics-ready for the tools robotics teams already run. Then train your robot in it, and take what it learns to the real one.
Every world here came out of SimFabric. Drag it, zoom it, then step to the next one.
Try SimFabric beta →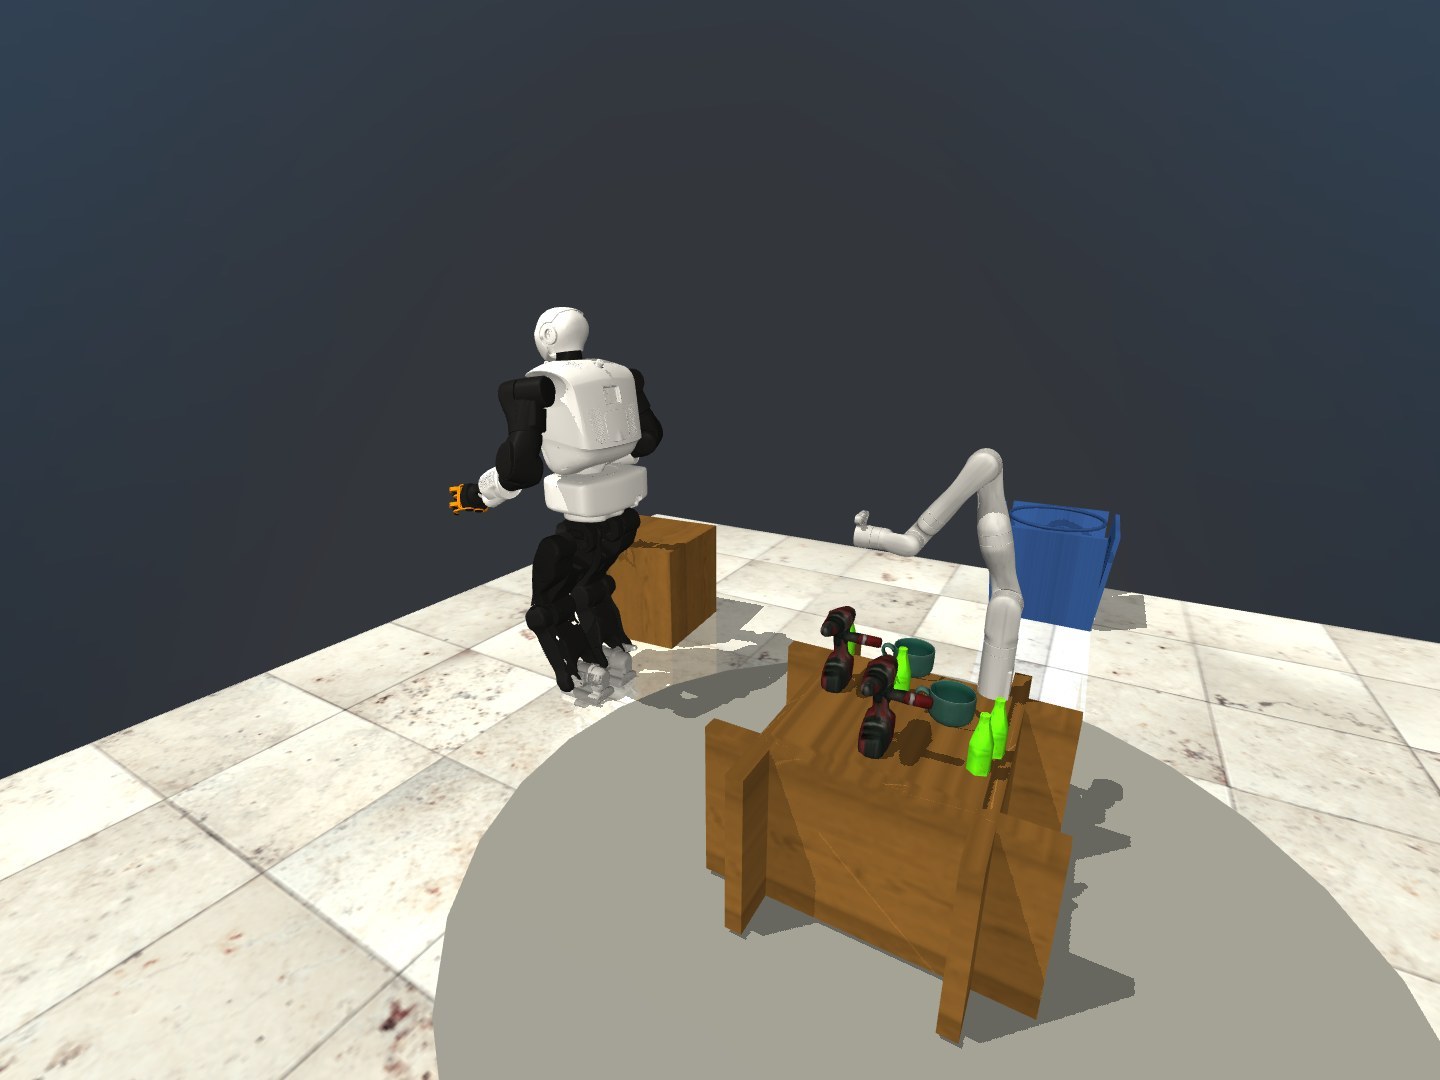
PROMPT“A tabletop pick-and-place cell: a 6-DOF arm mounted on a 0.9 m bench, a tote with 8 mixed YCB-style objects (mug, banana, drill, can), and a target bin 40 cm away.”
The operating thesis India / Everywhere
A robot in the field does not meet a clean laboratory floor. It meets clutter, uneven ground, unpredictable people, and work nobody rehearsed. That is the condition we design for.
The environments machines actually work in are cluttered, uneven and unrehearsed. We treat that as the starting condition rather than the edge case.
Simulation, assets, physics, training and evaluation, built as one system. The world a robot learns in and the way we measure it were designed together.
We care about papers, benchmarks and reproducibility, but the goal is infrastructure people can build on: tools and systems that hold up in production, not only in a result table.
Labs, manufacturers, integrators and research teams, wherever they are - if a machine has to perceive, plan or act in the physical world, Voxity would be the layer beneath it.
THE CAPABILITIES IN MOTION
We want to work with the teams, researchers and operators building machines that have to work in the real world.
info@voxity.org


