Vision tells a robot what something is. It doesn't tell it what's about to happen in the next fifty milliseconds of contact - whether a grip is holding, whether an object has started to slip, whether a surface is softer or rougher than it looks. That information only exists at the point of contact, and most manipulation systems still treat it as an afterthought: a binary touch/no-touch bit, if they use it at all.
Treating touch as a signal, not a switch
A few recent projects are pushing tactile sensing toward something closer to how vision or audio get treated - a continuous, information-rich stream that a policy learns from directly, rather than a threshold that trips a flag.
Visuo-Skin (ViSk), out of NYU, makes a specific and slightly contrarian bet: instead of the high-resolution optical tactile sensors most tactile-manipulation work uses (cameras looking at a deformable gel), they use low-dimensional magnetic skin sensors and feed that signal into a transformer policy as additional tokens alongside vision - no separate encoder, no dimensionality-reduction step. On four contact-rich tasks (credit card swiping, plug insertion, USB insertion, bookshelf retrieval) it outperforms both vision-only and optical-tactile baselines, with the biggest gains showing up specifically in spatial generalization. The interesting claim isn't “tactile sensing helps” - that's expected - it's that a cheap, low-dimensional signal, integrated the right way, can beat a more expensive high-resolution one.
eFlesh builds on the same magnetic sensing family from the hardware side - customizable, cut-cell microstructure touch sensing designed to be easy to fabricate and attach - and demonstrates it directly on slip detection and the same kind of visuotactile policy learning ViSk introduced, treating fingertip sensing as something you design into the hardware from the start rather than retrofit.
VibeAct takes a different physical channel entirely: instead of pressure or deformation, it reads contact and slip from vibro-acoustic signal - piezoelectric microphones embedded in a robot hand, picking up the sound and vibration of contact itself. It bridges real and simulated data by replaying the same recordings through a calibrated digital twin to automatically label per-finger contact and slip, so a tactile estimator can learn to predict contact and slip from real microphone waveforms while the manipulation policy trains in simulation on the exact same representation.
Why this is a signal, not yet a trend
We want to be straight about this one: it's a smaller, thinner body of work than the other three posts on this list. There's real depth in slip-detection research generally - the survey literature on tactile sensors for friction estimation and slip goes back over a decade - but the specific idea we're pointing at here, treating raw tactile signal as a first-class input a policy learns from directly rather than a hand-engineered feature, is still a handful of papers, not a wave. ViSk and eFlesh come out of the same lab lineage; VibeAct is a single paper exploring a genuinely different sensing channel. This is worth watching closely, not citing as settled consensus.
Where this connects for us
This is the sensing-side half of the full-duplex problem from our first post. An async control loop that's fast but blind to contact has nothing useful to react to quickly - the fast pathway needs a signal that updates as fast as it does, and vision alone doesn't provide that at the point of contact. Cheap, continuous tactile signal, read the way ViSk and VibeAct read it, is what would actually feed that loop. We think this is an early enough area that there's real room to contribute something original here.
Skin that knows when it's been touched, not just that it has
Everything above is about a robot sensing what it's doing to the world - grip, slip, contact force, in service of dexterity. There's an adjacent but genuinely different problem: a robot sensing what the world, specifically a human, is doing to it. Vision tells a robot what's in front of it, and force sensors at the joints give it a handful of discrete contact points, but almost none of a humanoid's actual surface feels anything. Most of the body is functionally numb. That matters for physical human-robot interaction and safety, not for manipulation dexterity, which is why it earns its own slot here rather than folding into the tactile-sensing work above.
This is a healthier body of work than the tactile-sensing area above - three genuinely different bets on the same problem, published across a five-year span. Teyssier et al. optimizes for feeling human: a silicone-layered, human-skin-mimicking capacitive sensor with an open-source sensing board, characterized down to 0.5mm spatial acuity and force response up to 5N - contact that feels intuitive to the person touching the robot. Rustler, Misar & Hoffmann (Humanoids 2024) optimizes for provably safe: adaptive electronic-skin sensitivity tied directly to the ISO/TS 15066 collaborative-robot safety standard, adjusting sensitivity based on the colliding link's effective mass and speed rather than a fixed threshold. A December 2025 PNAS paper out of City University of Hong Kong optimizes for fast: a neuromorphic robotic e-skin with active pain and injury perception, triggering reflex-like protective responses locally without waiting on central processing, with a modular, replaceable design so damaged patches can be swapped out.
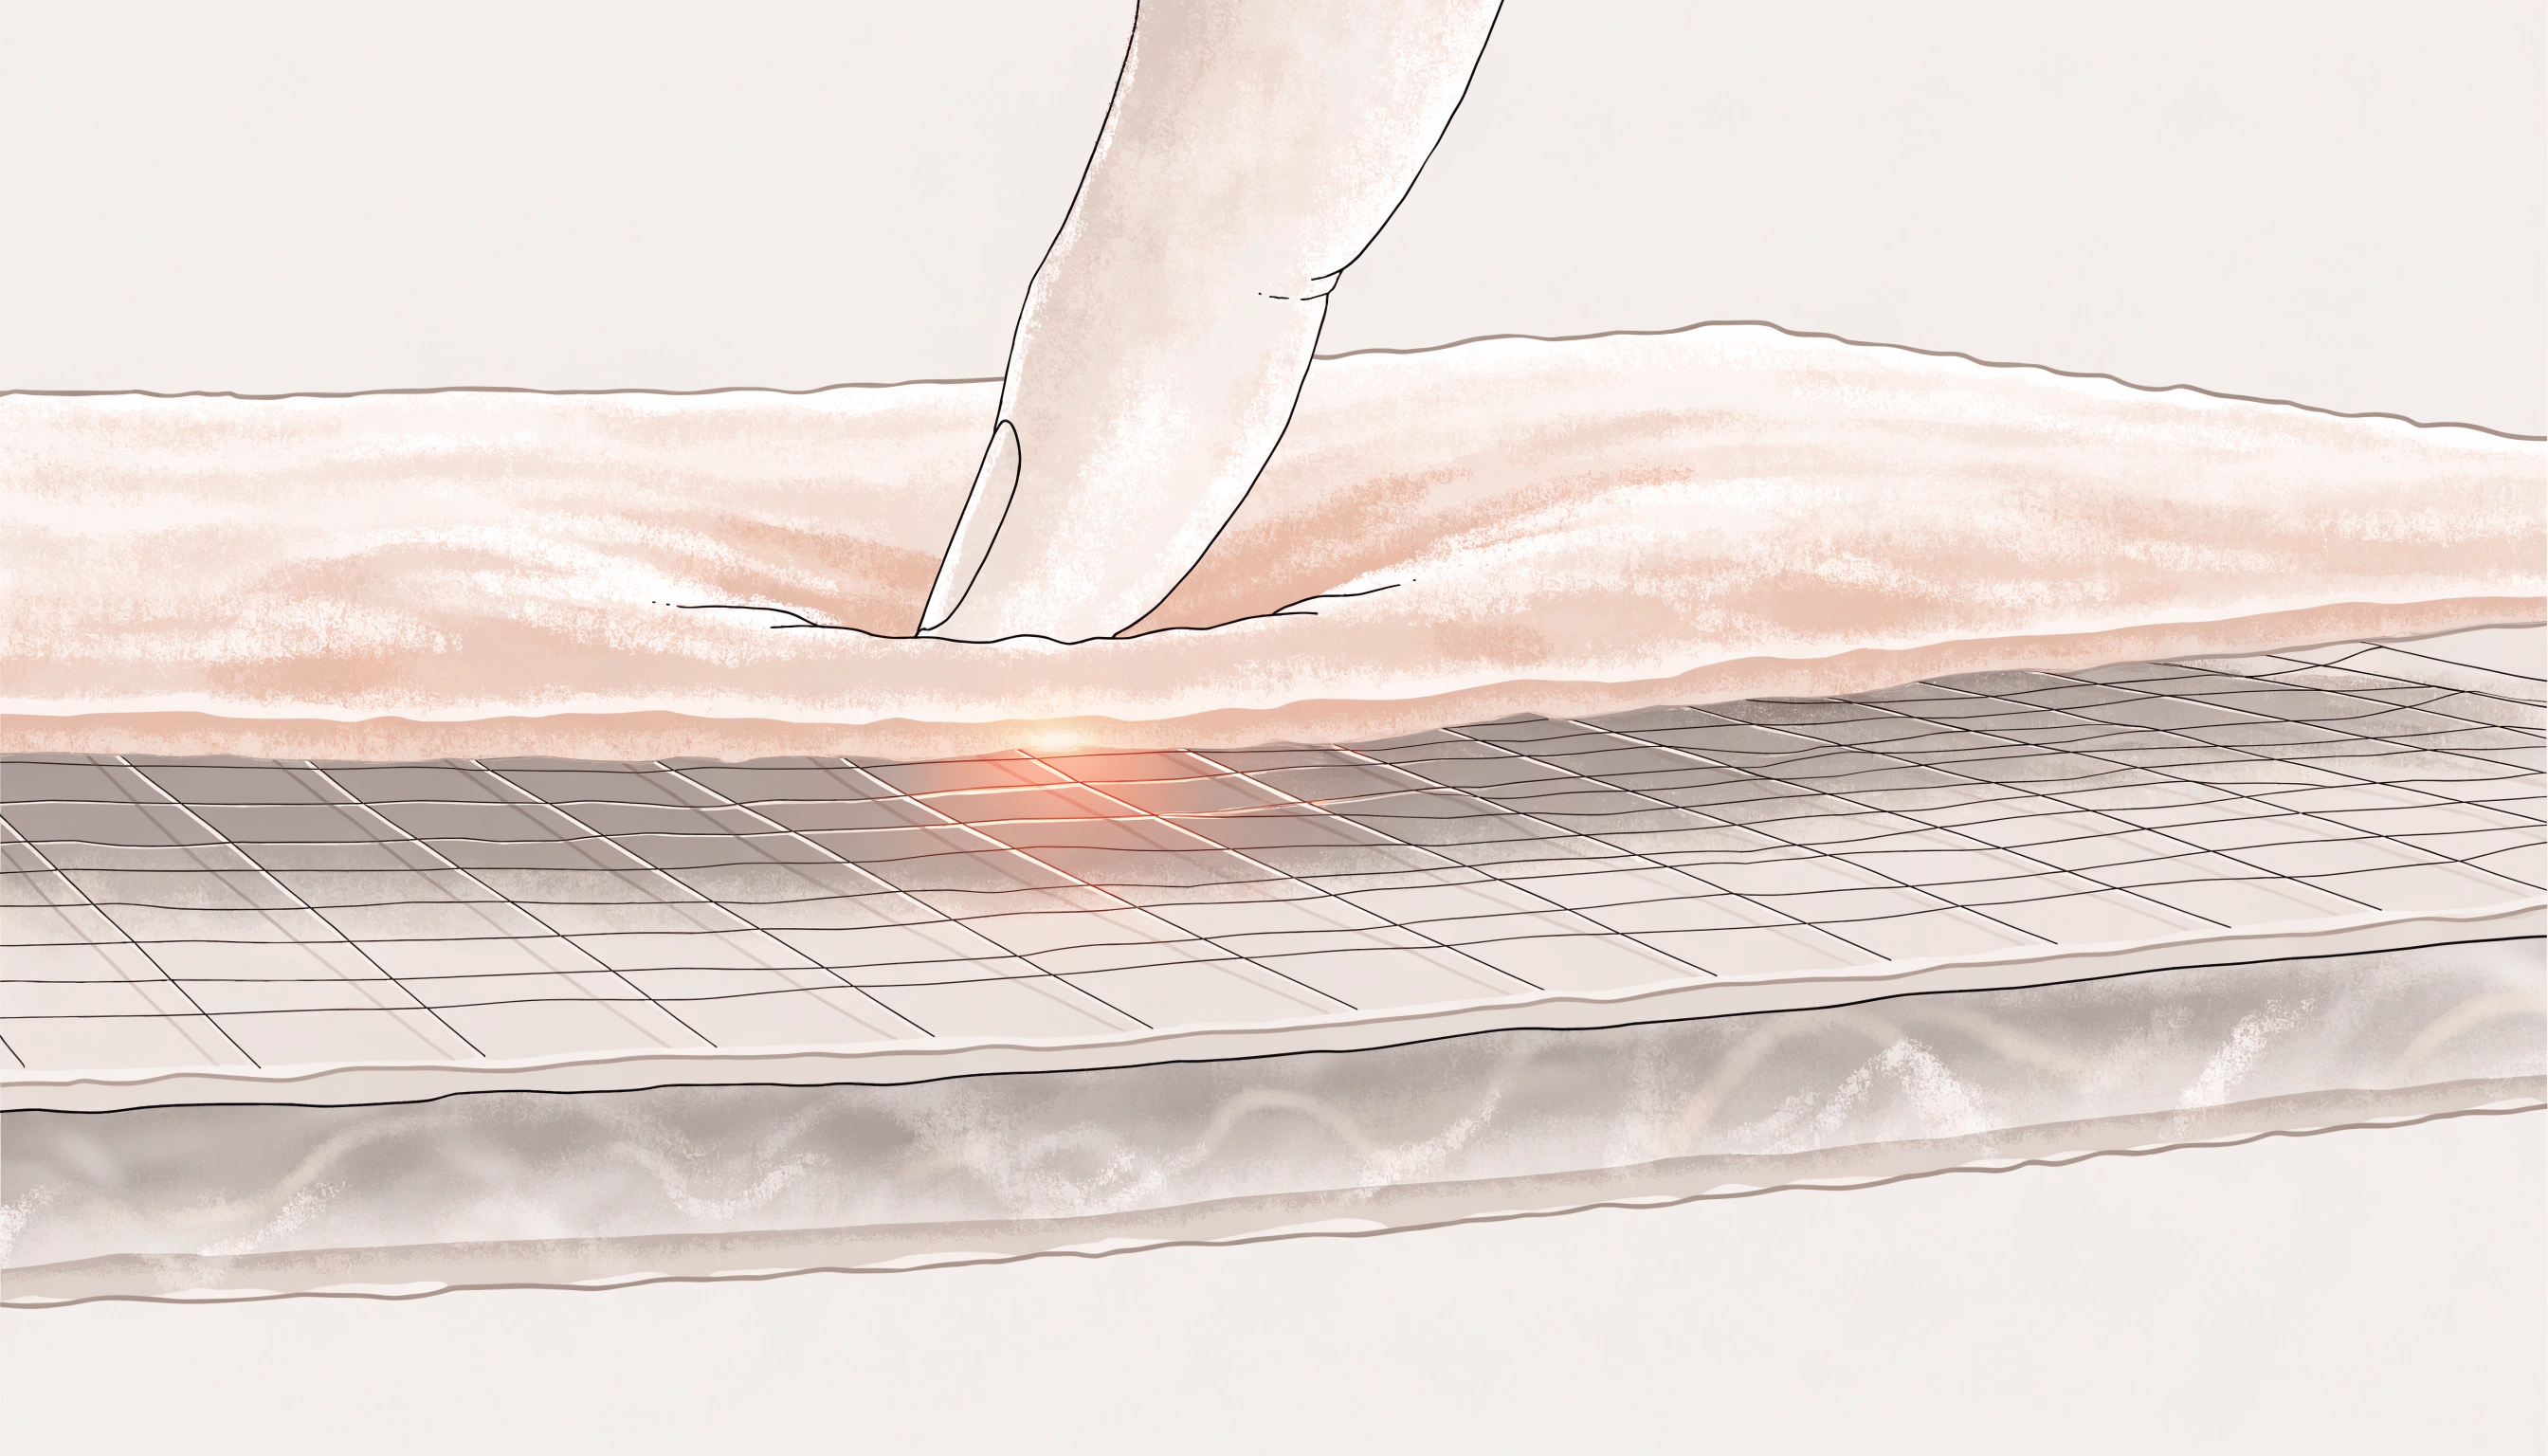
There's an honest tension between these three approaches that none of them has resolved: soft, human-like silicone skin and reflex-fast neuromorphic response are somewhat in conflict - softness adds mechanical latency, and speed usually wants a stiffer, simpler sensor. Nobody has shipped both properties in one skin yet. Feeling human, being provably safe, and reacting fast are three different design targets, and current work picks at most one to optimize hard for.
This is why we treat it as a different problem from the tactile-sensing work above, not a subset of it. Manipulation dexterity is about a robot sensing what it's doing to the world. Whole-body skin is about a robot sensing what the world - specifically, a human - is doing to it. Both matter for a company that eventually wants to go deep into hardware, but this is the safety and interaction half of that, not the dexterity half.
References & further reading
- Learning Precise, Contact-Rich Manipulation through Uncalibrated Tactile Skins (Visuo-Skin / ViSk), arXiv:2410.17246
- eFlesh: Highly Customizable Magnetic Touch Sensing using Cut-Cell Microstructures, arXiv:2506.09994
- VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity, arXiv:2606.27344
- Teyssier, Parilusyan, Roudaut & Steimle - Human-Like Artificial Skin Sensor for Physical Human-Robot Interaction, ICRA 2021
- Rustler, Misar & Hoffmann - Adaptive Electronic Skin Sensitivity for Safe Human-Robot Interaction, Humanoids 2024, arXiv:2409.06369
- A Neuromorphic Robotic Electronic Skin with Active Pain and Injury Perception, PNAS, December 2025